

This week we’re publishing a series of five articles about the state of robotics — we’re calling it Robot Week. It’s the most ambitious project we’ve ever undertaken. Over the last nine months, I’ve read dozens of research papers, Kai has gone on five reporting trips (including one to China), and we even purchased a robot dog from China!
Our goal is to help readers understand the pace of progress in robotics — and the implications for the economy. How close are today’s robots to human-level performance? What are the biggest problems remaining to be solved?
Our first two articles (including this one) will be free, but the final three will be exclusively for paying subscribers. This week we’re also offering 25% off an annual subscription. So it’s a great time to upgrade. Click here to get the 25% Robot Week discount!
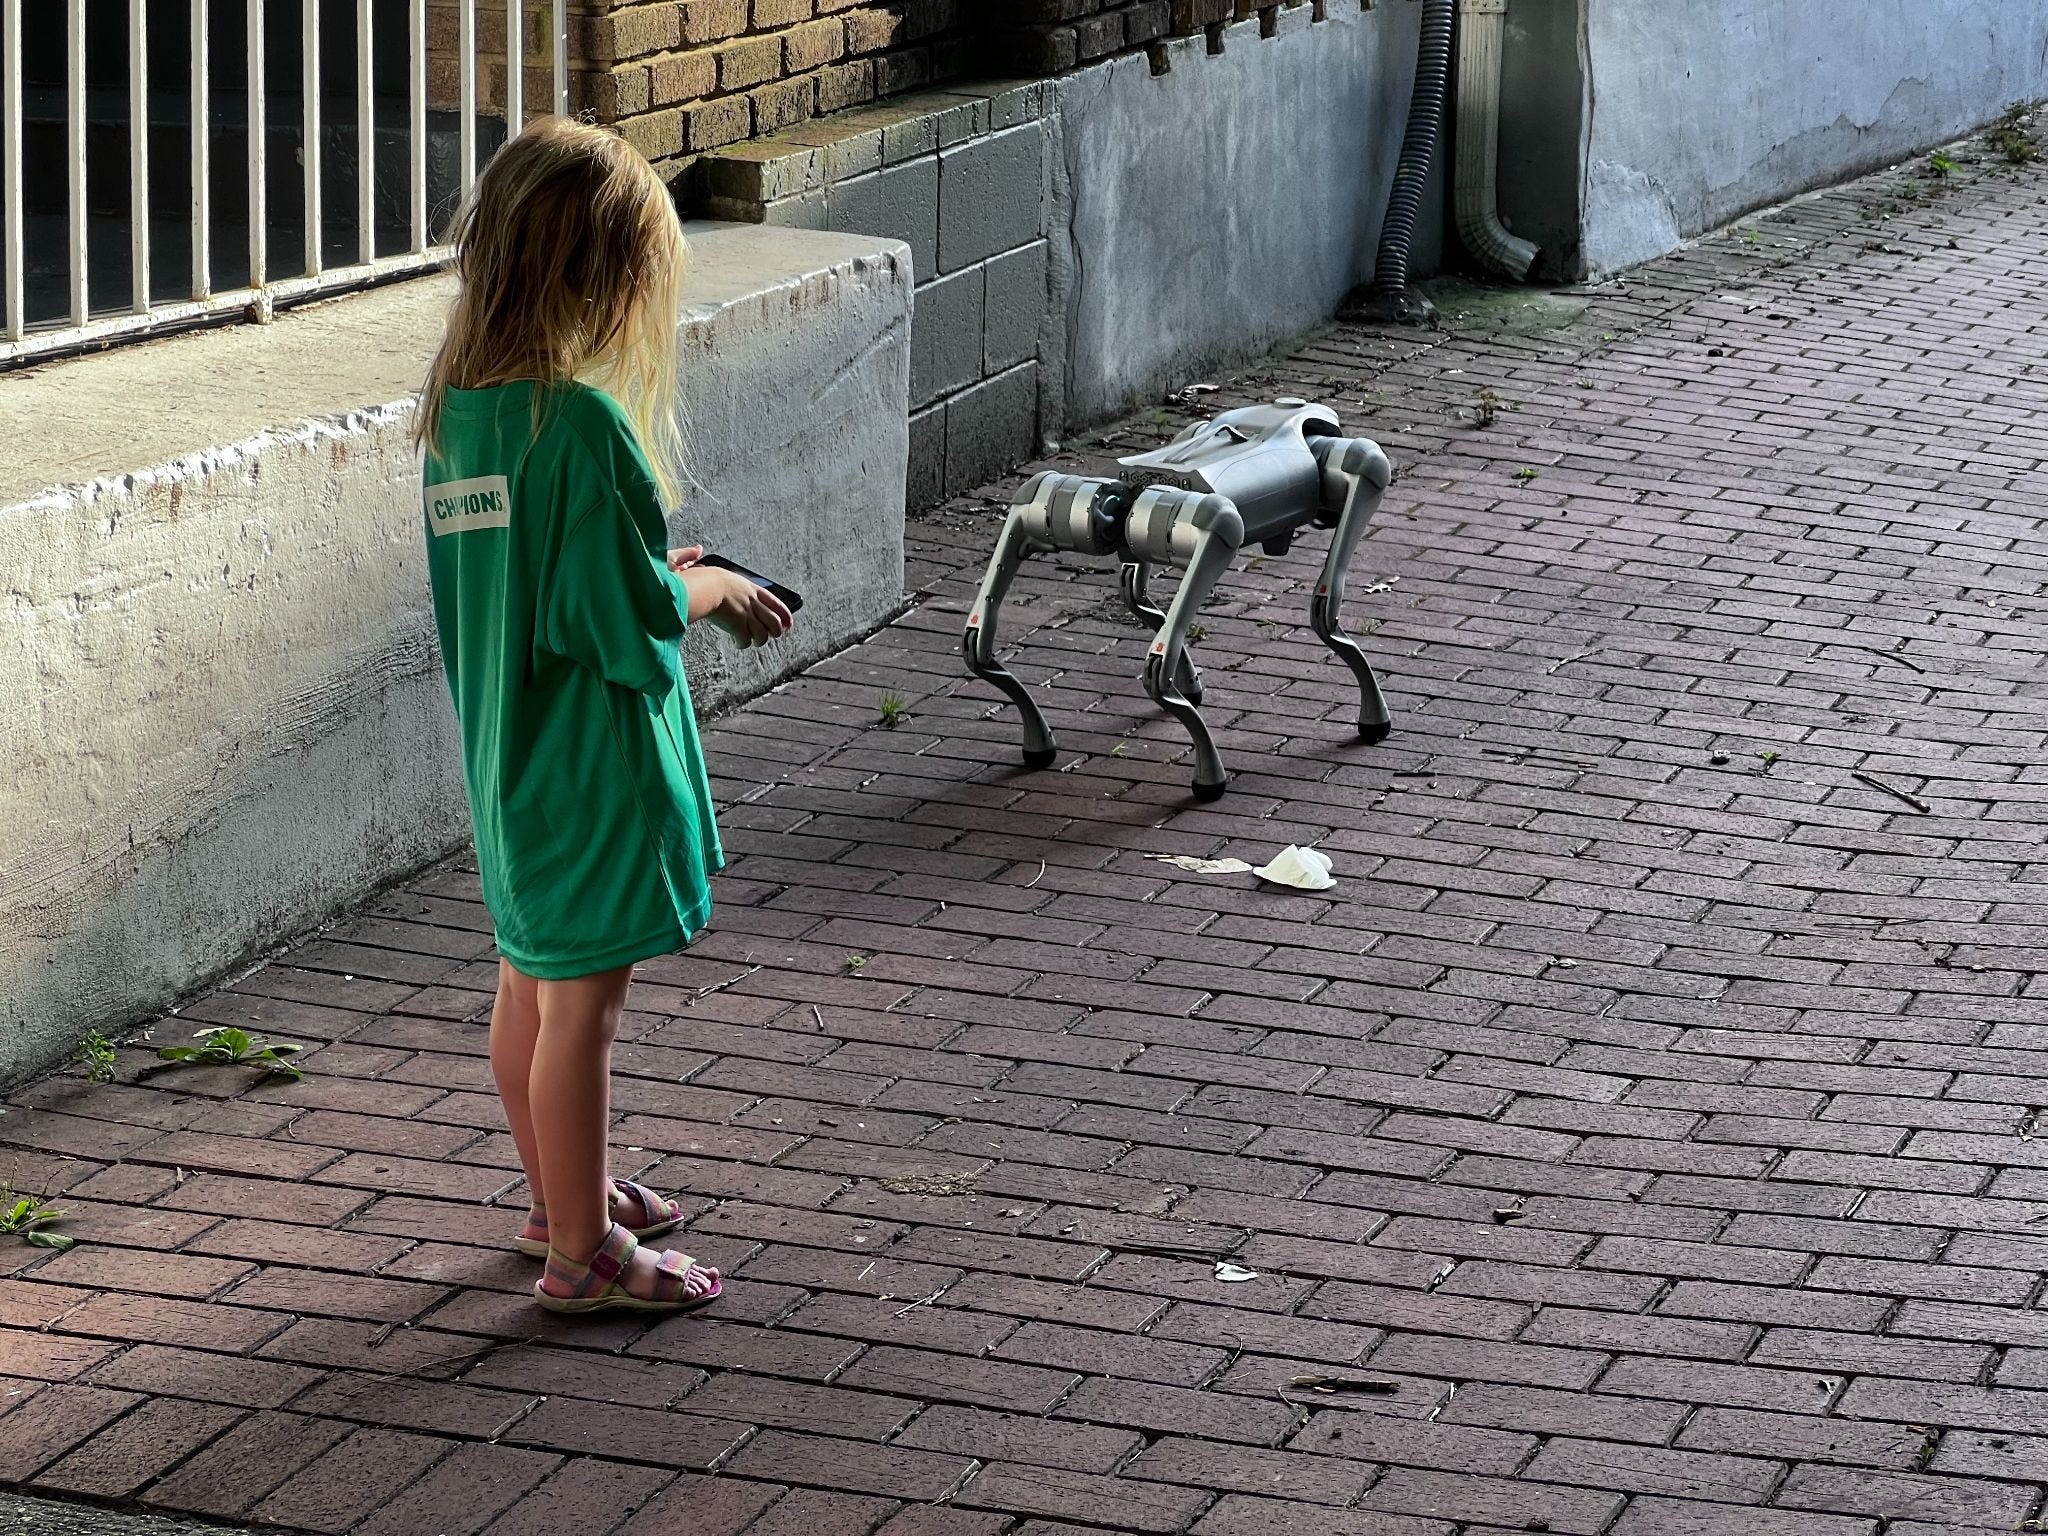
On a sunny morning in June, I walked to work with a quadruped robot beside me. I’ve never gotten more attention from strangers.
A bunch of people snapped pictures of my robot dog. Several people asked me questions. Was it mine? (Yes.) Did I build it? (No.) Was it being used for surveillance? (No.)
Biological dogs kept a safe distance from my mechanical companion. Some growled or barked at it.
Children were fascinated. I paused and had it do tricks for several of them: “shake hands,” do a handstand, or leap into the air.
I live in a leafy Washington DC neighborhood called Mount Pleasant. The neighborhood lives up to its name, so my morning commute is mostly downhill. My robot companion, manufactured by the Chinese company Unitree, walked the two miles to my office near the White House with battery capacity to spare.
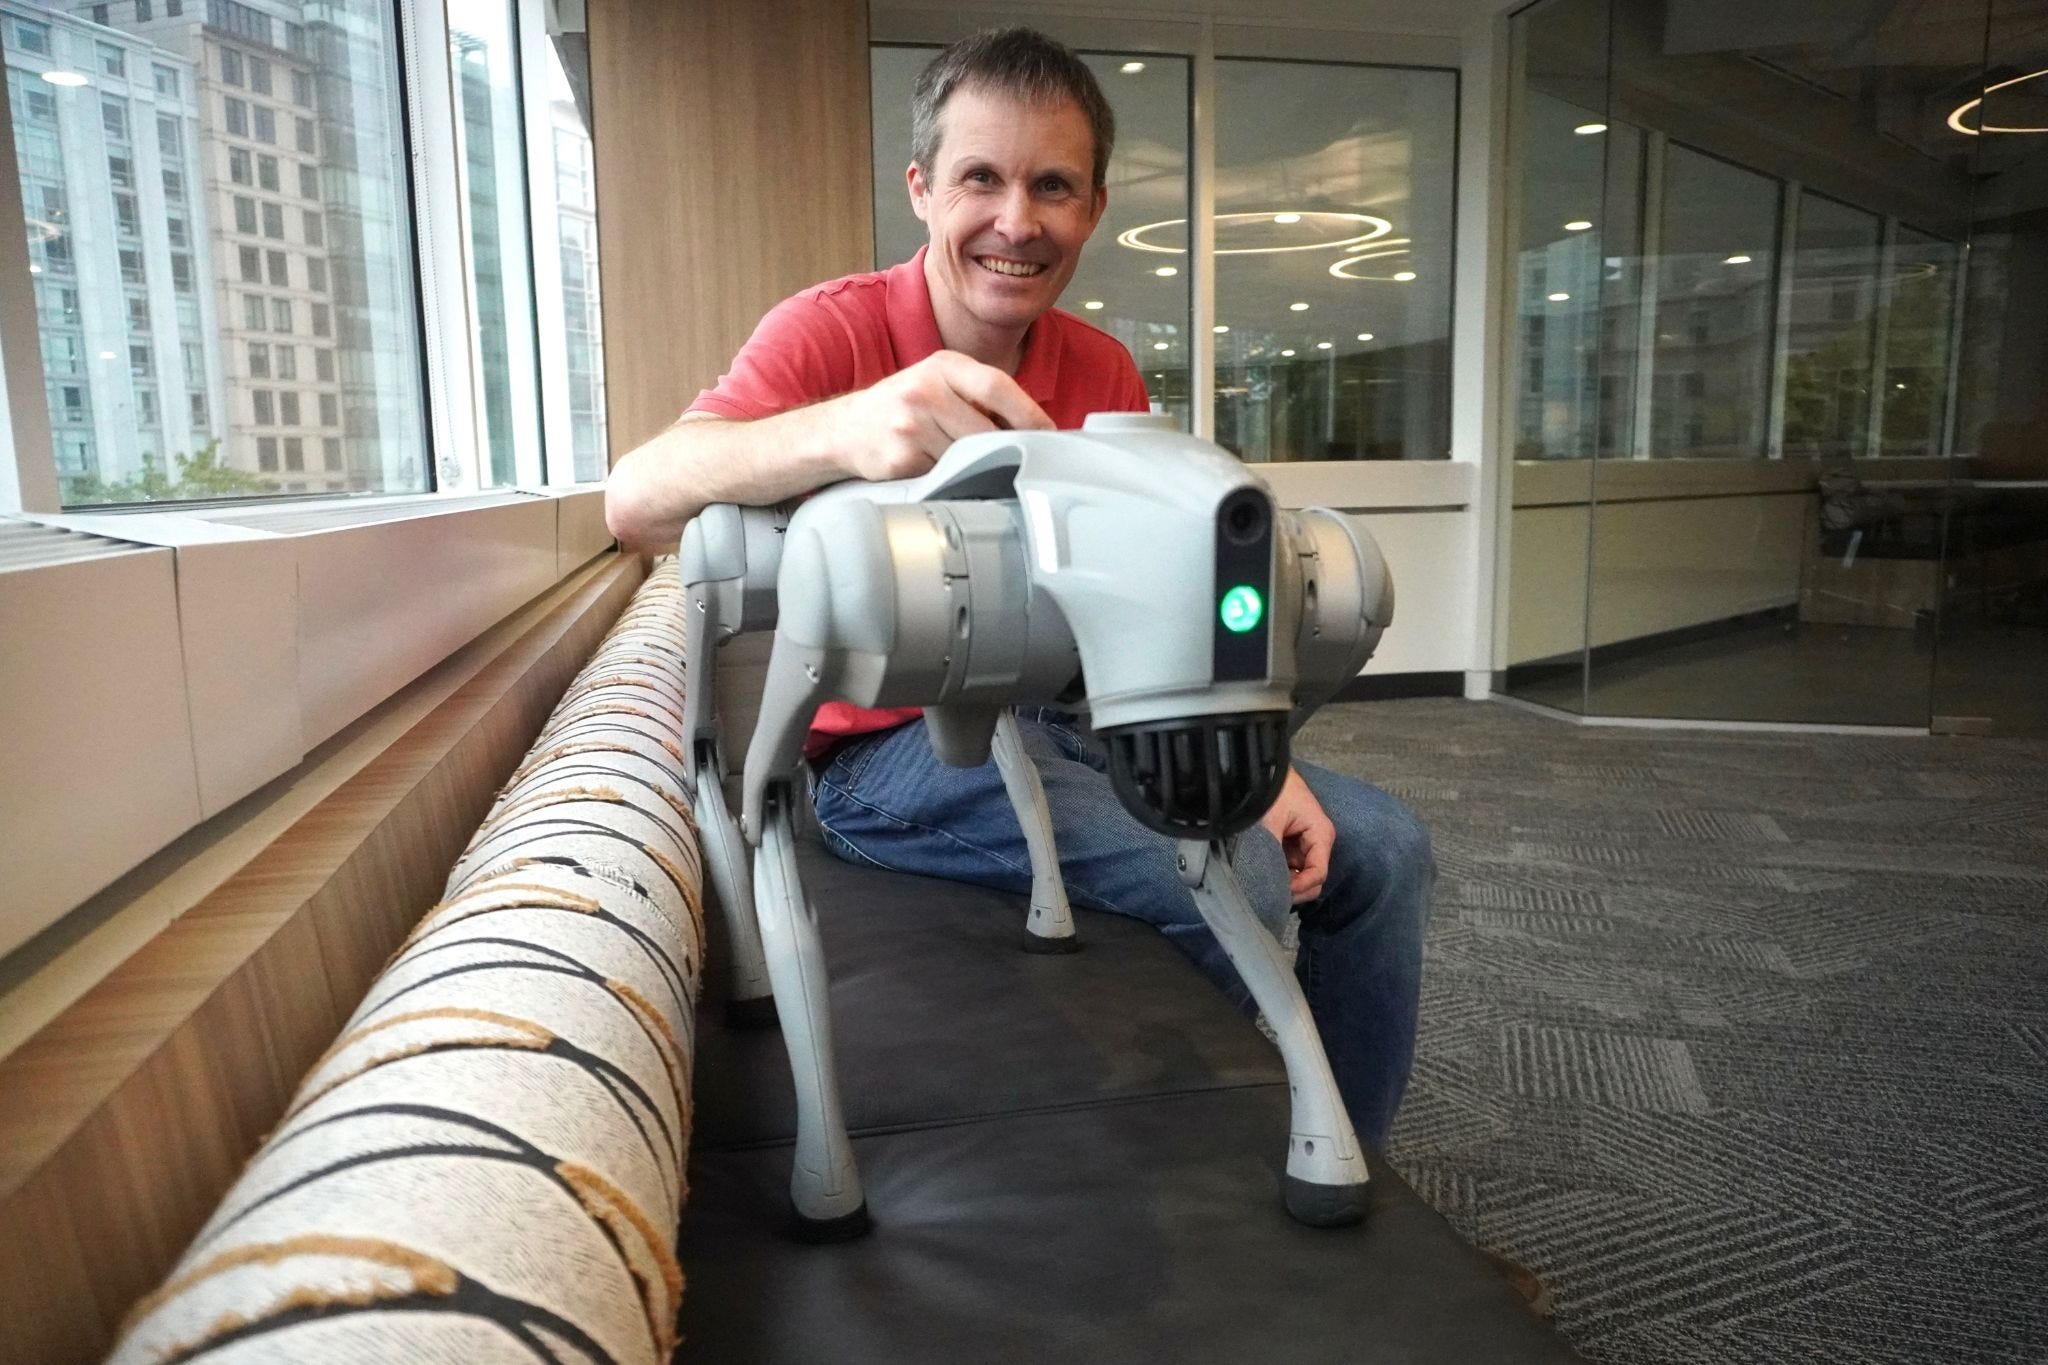
I recharged the battery during the workday, but it still struggled on the afternoon walk home. We were now mostly walking uphill, and the temperature had risen to 87°F (30°C). The robot’s steps seemed increasingly labored as the path got steeper.
As I entered my own neighborhood, I glanced at two indicators in the corner of my phone screen. One showed that the robot’s battery was at 5% — dangerously close to empty. The other showed the internal temperature was 84°C — 183°F.
We were within sight of my front door when the robot suddenly collapsed. I’m not sure if it ran out of power or overheated, but either way it didn’t shut down gracefully — it rolled onto its back with its legs in the air.
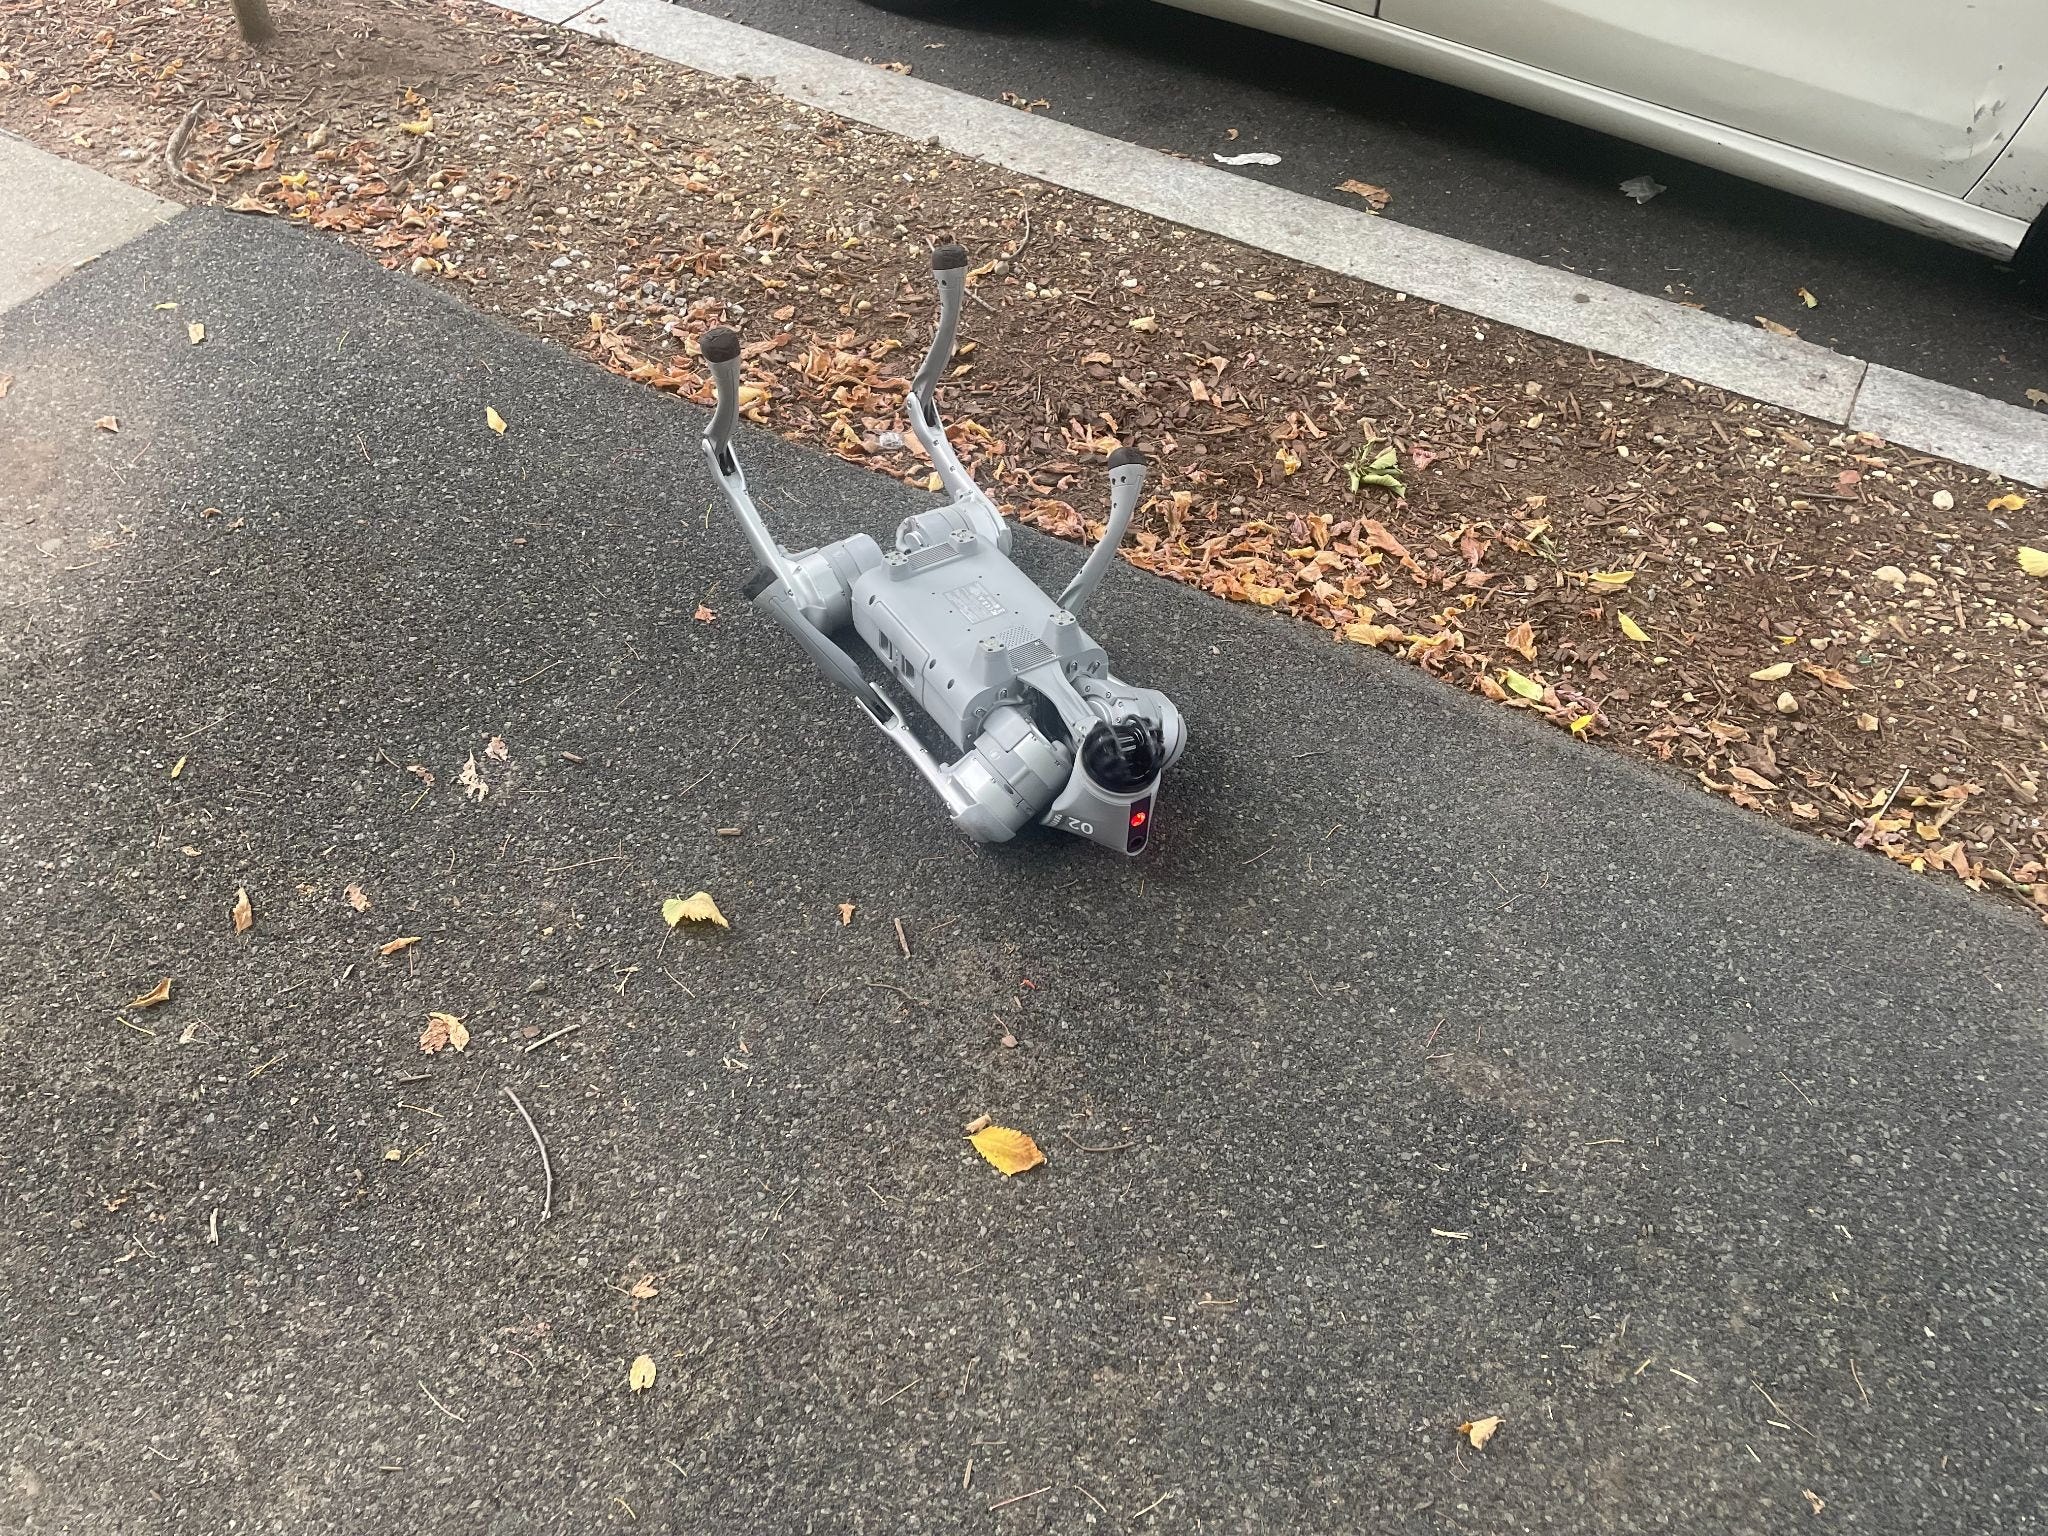
Several people have asked me what my robot is useful for, and the honest answer is not much.
Unitree quadrupeds are widely used for academic research and they are sometimes used for entertainment. But there don’t seem to be a ton of practical applications.
Wheeled robots are faster and more energy-efficient, making them better for deliveries. Flying drones are a better choice for a lot of surveying and inspection work. My robot has no arms or hands, making it mostly useless around the house.
But my robot did have one big thing going for it: it was astonishingly cheap.
I paid $4,017. That’s more money than I’ve ever spent to review a product. But it’s also far less than I would have had to pay for this type of robot a few years ago. And it’s cheap enough that people may find uses for it that wouldn’t have made sense at higher prices.
Sometimes what changes the world isn’t the invention of a new technology, it’s figuring out how to make it affordable enough for a mass market. Xerox built the first personal computer with a graphical user interface, but companies like Apple, IBM, and Microsoft made the technology mainstream. Perhaps Unitree will play a similar role for quadruped robots — though as I’ll discuss later, Unitree’s robots now face legal restrictions in the United States.
Unitree has also used quadruped robots as a stepping stone to another market that could be much more important — humanoids. Unitree launched its first humanoid robot in 2023. Leveraging its experience making cheap quadrupeds, Unitree is able to sell humanoid robots for as little as $13,500.
That’s still way out of my price range, which is why I bought a robot dog instead. But it’s dramatically cheaper than any humanoid you could buy a few years ago. And the low cost has made Unitree a global leader in humanoid robots.
Financial markets are bullish. Unitree debuted on the Shanghai stock market on August 19. On its first day of trading, shares shot up more than fivefold. It has lost some altitude since then, but at Monday’s closing price, the company was still valued at $34 billion — more than triple its valuation before the IPO.
How Unitree democratized legged robotics
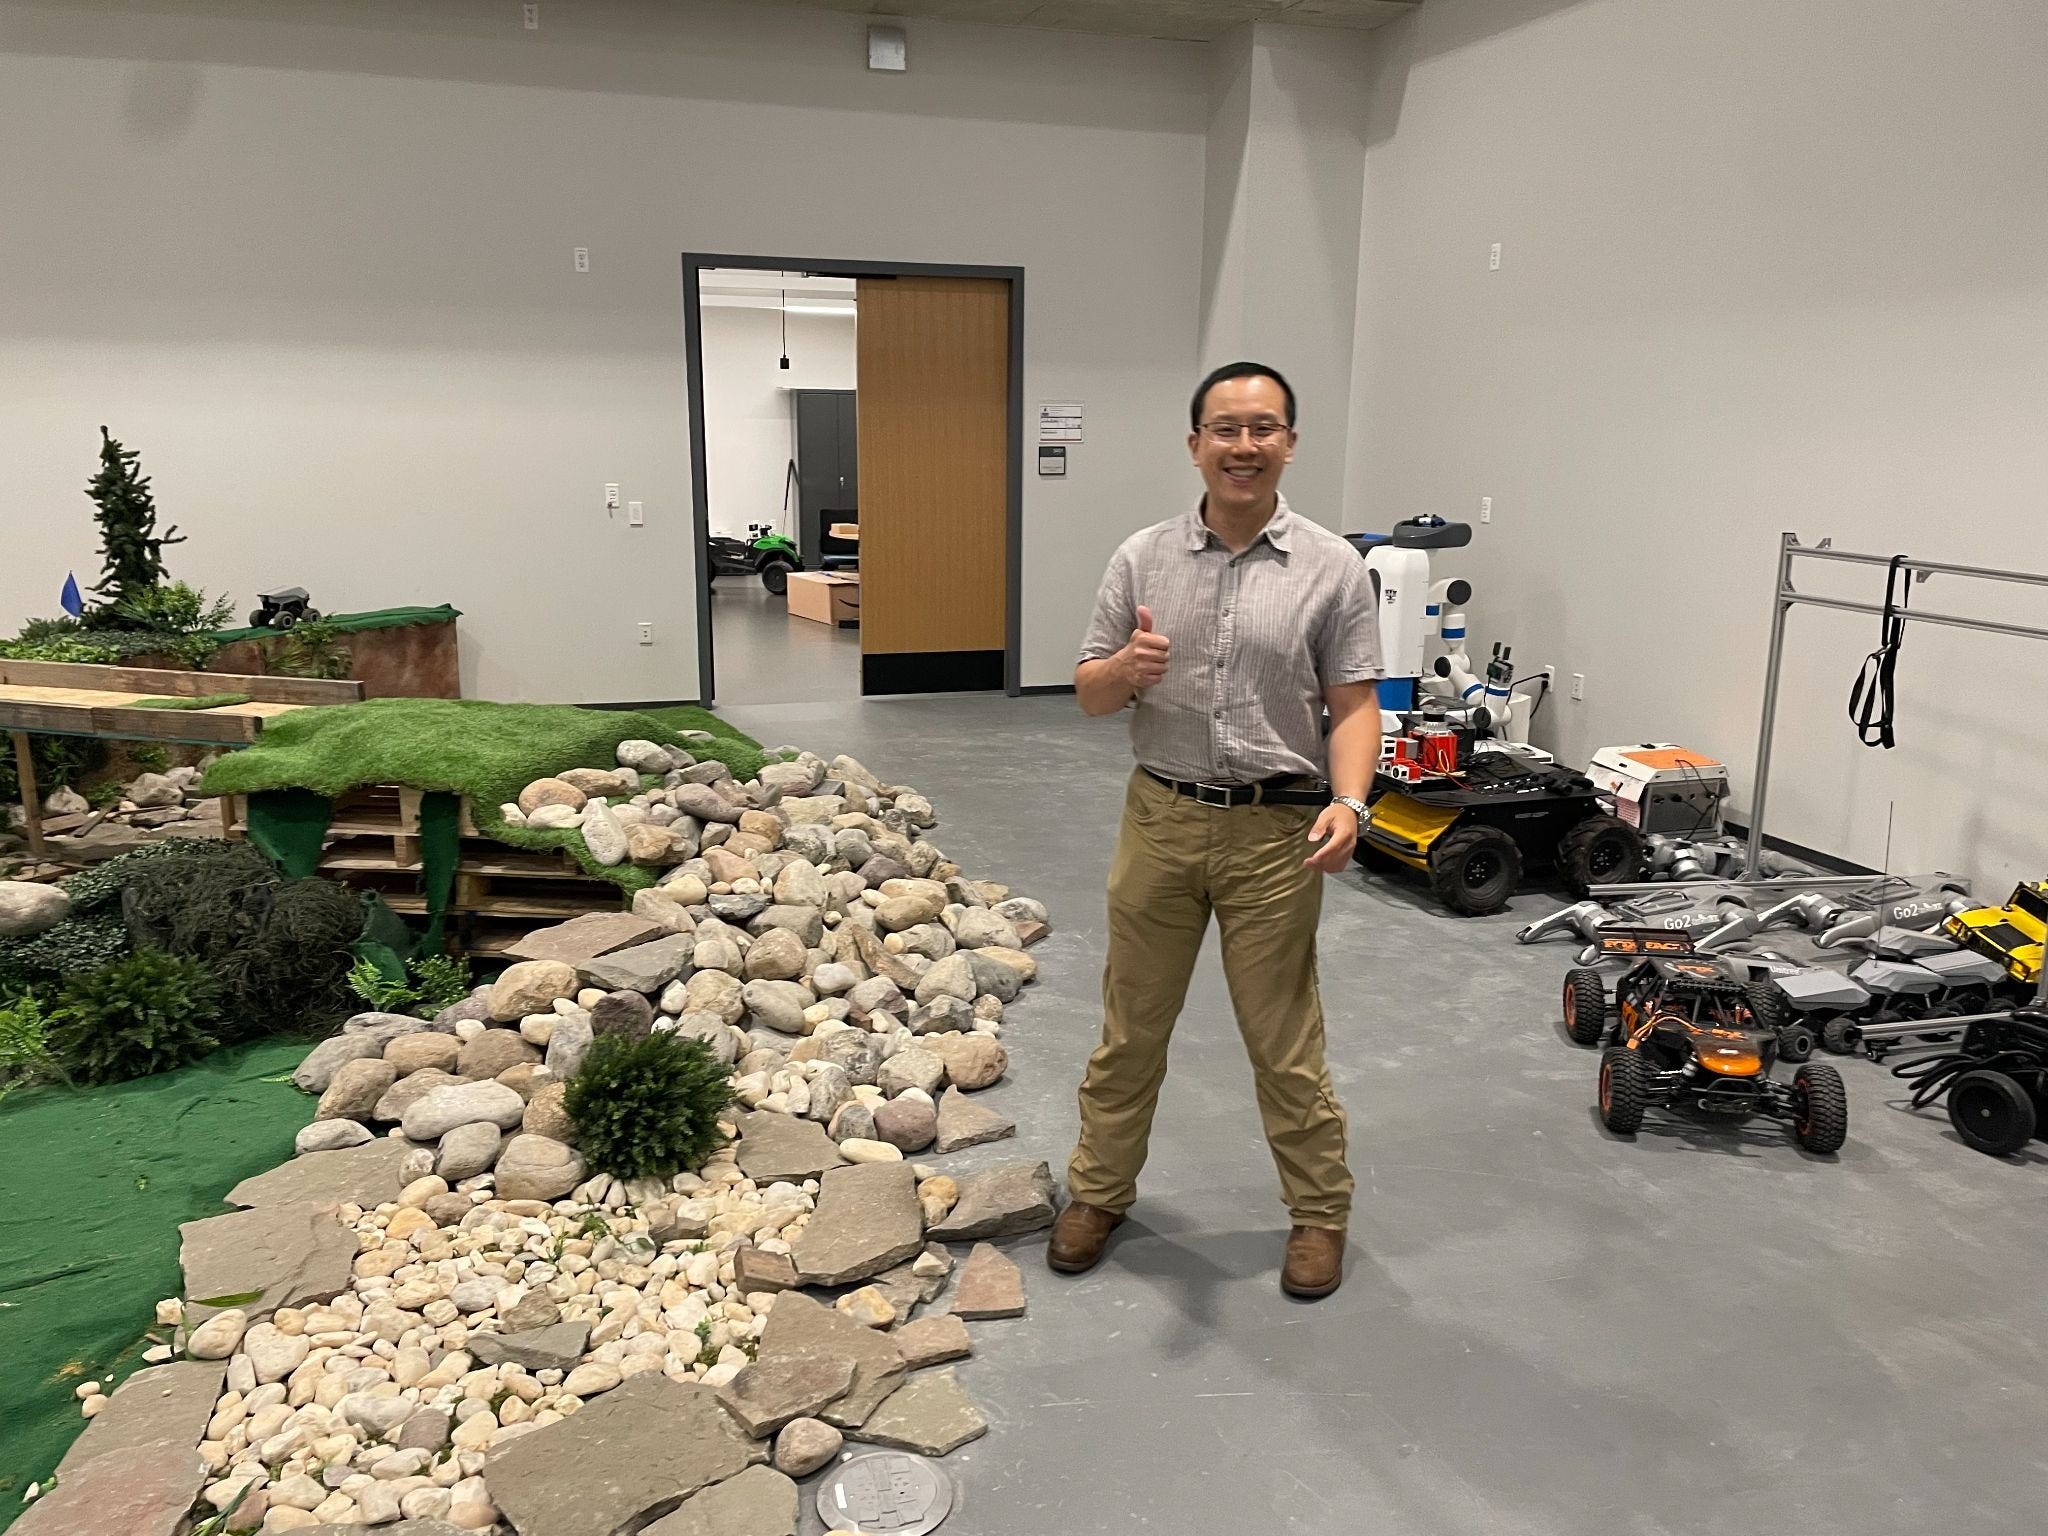
Earlier in June, I visited Prof. Xuesu Xiao, a roboticist at George Mason University.
“Ten years ago, only a very small set of research groups were working on quadruped locomotion because they were the only people on the planet who could build a quadruped,” Xiao told me. “Then Unitree came onto the market. And it basically democratized the entire world of quadruped locomotion research.”
Xiao gave me a tour of his lab, which had four Unitree quadrupeds. Each cost around $15,000. The lab also had a quadruped robot called Spot. It was made by Boston Dynamics — widely seen as the industry leader before Unitree came along. But Spot is expensive, starting around $75,000.
Unitree founder Wang Xingxing developed a crude quadruped robot called XDog for his master’s thesis at Shanghai University.
“Marc Raibert from Boston Dynamics is my idol,” Wang told IEEE Spectrum in March 2016. “Their papers helped me to design XDog.”
Early Boston Dynamics prototypes — with names like BigDog and WildCat — had gasoline engines and hydraulic actuators. This made them too large, noisy, and polluting for practical use.
In that 2016 interview, Wang said that his goal was to “make quadruped robots simpler and smaller, so that they can help ordinary people with things like carrying objects or as companions.”
Boston Dynamics officially unveiled an electric quadruped called Spot in June 2016. But Spot didn’t become commercially available until 2020.
That created an opening for Unitree, which Wang founded in May 2016. The company’s first quadruped products — Laikago in 2017 and AlienGo in 2019 — were powered by electric motors. Designed for research labs, they cost tens of thousands of dollars.
In 2021, Unitree launched the Go1 line, which started at $2,700 for the “Air” model. In 2023, Unitree unveiled the Go2, which was even cheaper — $1,600 for the Air and $2,800 for the more capable Pro.
Today, Unitree’s cheapest robot — the Go2 Air — is more than 97% cheaper than Spot. But this is not an apples-to-apples comparison; Spot is larger than Unitree’s Go2 line and can carry heavier payloads.1
Still, the fact remains that Unitree made quadruped robots affordable to many people who could never afford Spot — including me! My wife never would have let me spend $75,000 or even $15,000 on a robot dog. But I convinced her to let me spend $4,017 (after tariffs and shipping costs) on a Go2 Pro.2
Why are Unitree robots so cheap?
Last year the firm Simplexity tore a Go2 robot dog apart and made a video showing what they found.
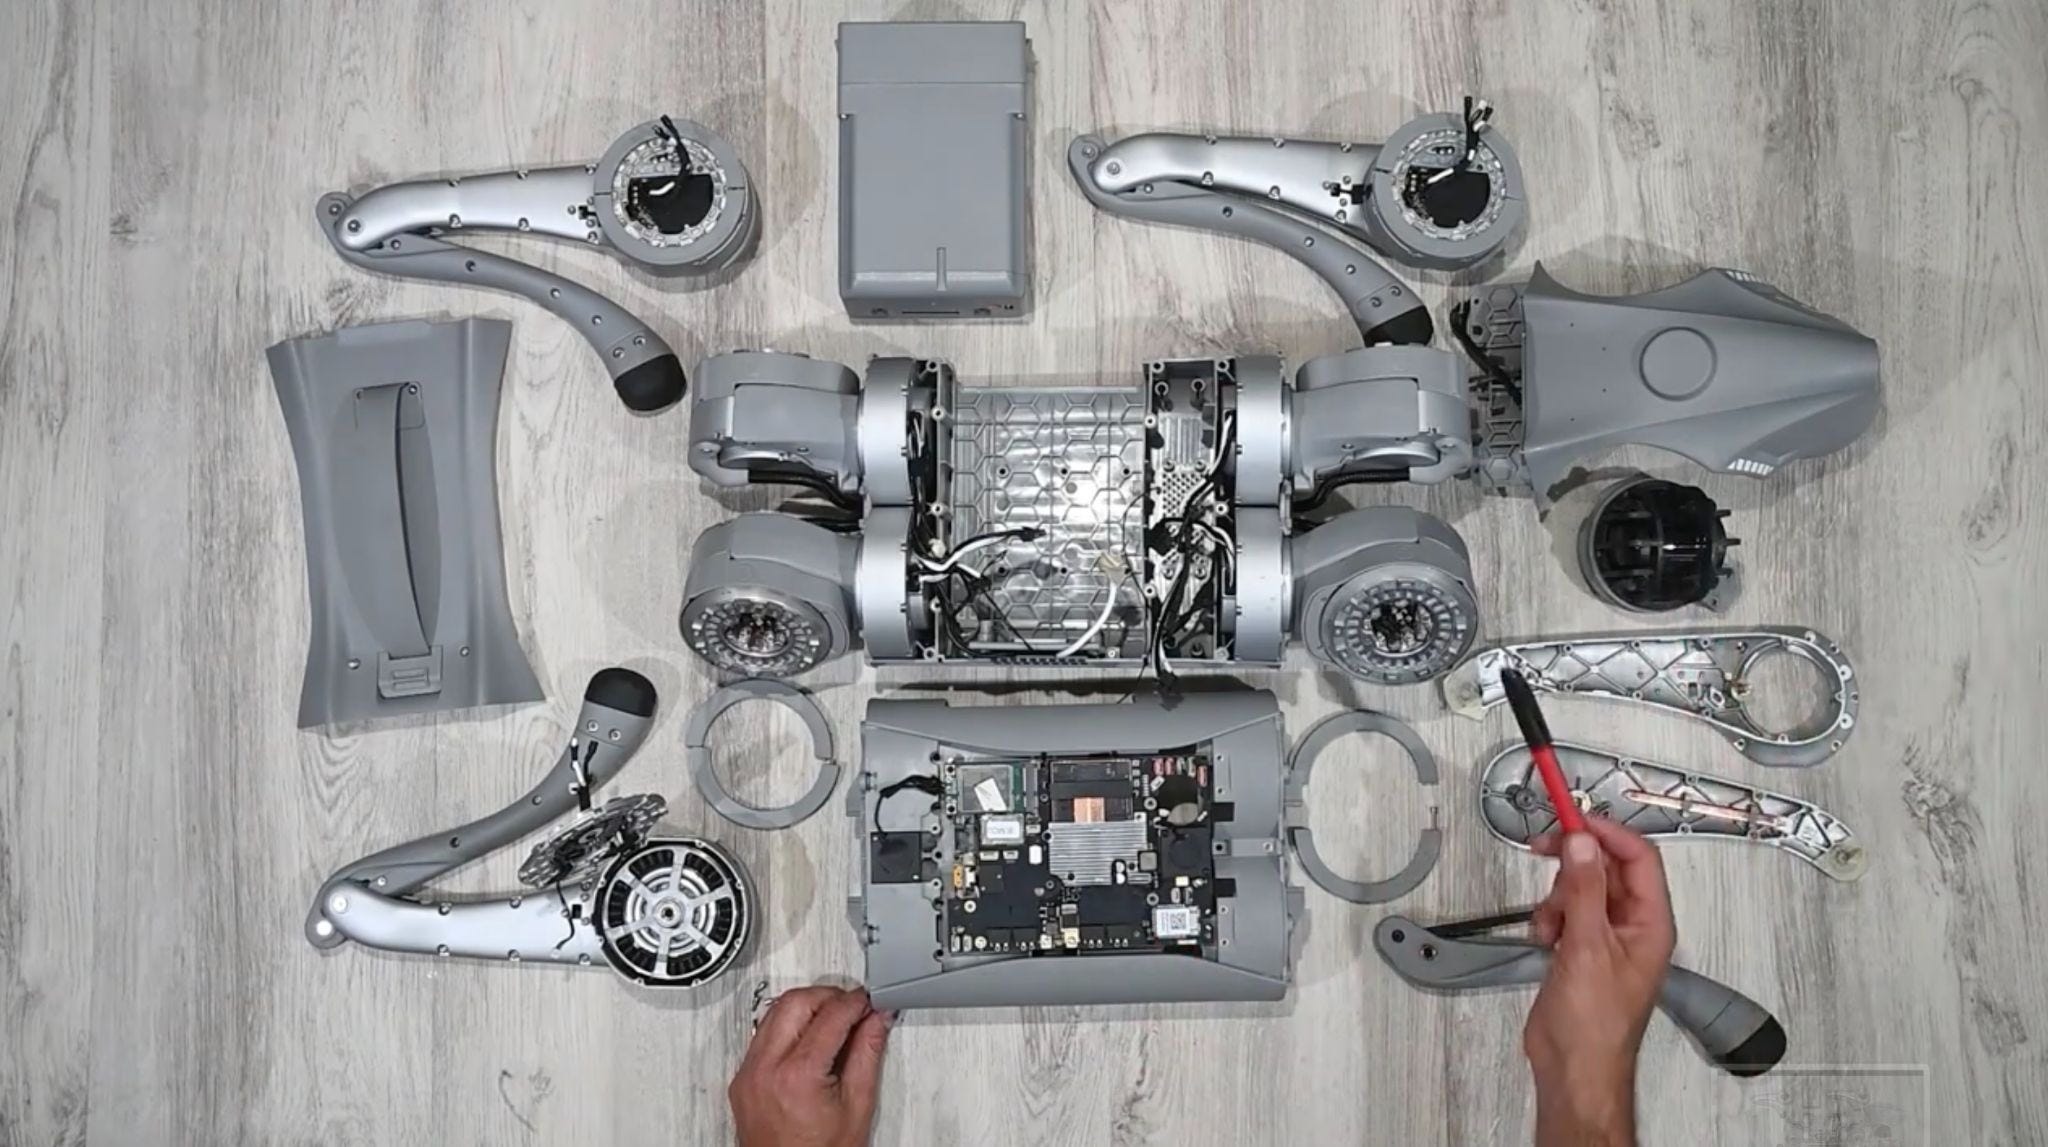
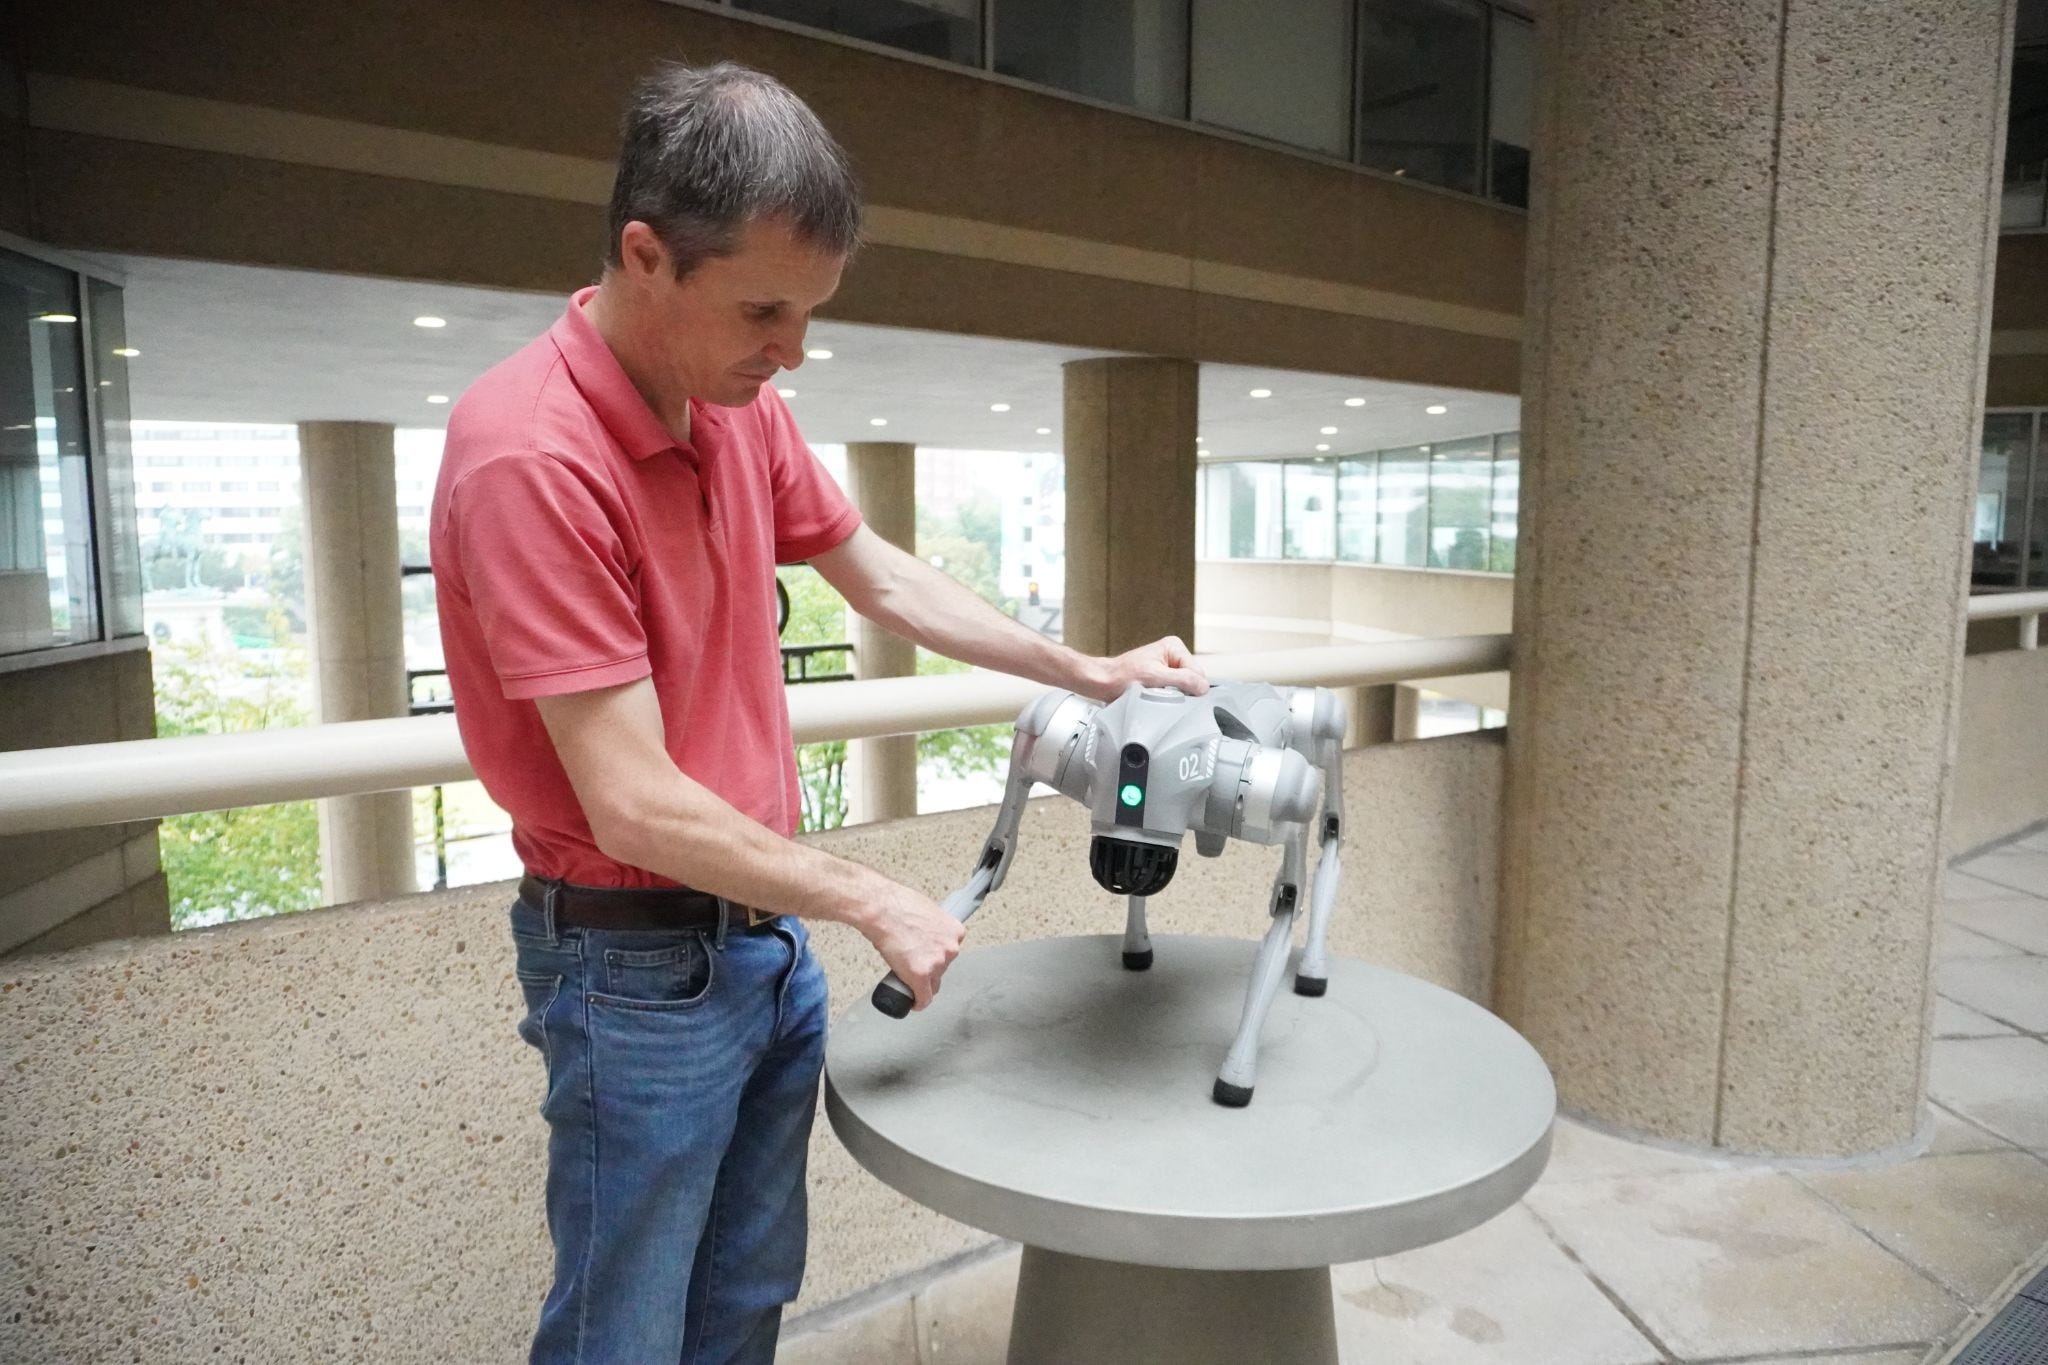
Each of the robot’s four legs is powered by three motors. There’s a motor in the shoulder that controls the angle of the legs and a motor driving each of the two leg segments. “With three motors, you get a really dynamic range of motion,” said Luis Elenes, a mechanical engineer at Simplexity.
“They use all the same motors throughout,” Elenes added. “All four shoulders are identical in arrangement. There’s tons of benefit to that. There’s reduced cost, there’s reduced part count. The more you can reuse motors and reuse parts, the simpler your design gets, and the more robust overall your design will be.”
Jakub Bartoszek, an expert on motors and legged robots at the startup MAB Robotics, argues that Unitree also saved money by using low-quality components. The motors in Unitree robots — many of which are made in-house — tend to wear out more quickly than those in some other robot brands, he told me. But the cost savings make the robots affordable to more people.
Unitree seems to have designed its robots for easy repairs when they wear out.
“They want these legs to be serviceable in the field,” Elenes said. Thanks to the simple way the robot’s legs are attached to its body, “you can swap out a leg pretty easily. I would guess it would take you less than a minute.”
Unitree also gets significant support from the Chinese government, including tax credits and large-scale purchases by public institutions. It’s hard to quantify the scale of this support because the Chinese system blurs the line between public and private, military and civilian. But a supportive policy environment clearly helped Unitree to scale up its manufacturing operations and thereby drive down the cost of each robot.
How powerful motors enable cheap actuators
Unitree has another counterintuitive cost-saving strategy: using large and powerful motors. More powerful motors aren’t inherently cheaper, of course. But they allow Unitree to save money on another component called the reducer that can be even more expensive
Suppose you have a lever where one side is five times longer than the other. If you push the long side down by five inches, the short side goes up by just one inch. But force is magnified: 10 pounds on the long side becomes 50 pounds on the short side.
Many robots use gear systems called reducers that serve the same function; they convert the fast, relatively weak movement of an electric motor into a slower but stronger movement of a robot’s body parts.
Traditional industrial robots require extreme precision, so they tend to have large reduction ratios.
A page on the Boston Dynamics website, for example, indicates that two of the motors in Spot’s legs are paired with reducers that have gear ratios of 51-to-1. In other words, the motor would need to do 51 full rotations in order to produce one full rotation of a leg joint.
This enables Spot’s movements to be very precise while magnifying the power of Spot’s motors. But it also has some disadvantages. One is cost. Reducers with 51-to-1 ratios are complex and — as a result — tend to be significantly more expensive than reducers with lower ratios.
Another is rigidity. When a robot’s arm encounters physical resistance, it should yield gracefully — a property called backdriveability. It’s also helpful if a robot can sense this kind of physical resistance electrically. Robots with higher gear ratios perform badly on both these fronts; their limbs feel stiffer and they are less sensitive to physical resistance.
In contrast, Unitree uses large motors combined with a simple 6.33-to-1 gearbox. This makes its robots more nimble and dynamic while reducing costs. The simpler design is also easier to simulate, making Unitree robots easier to train.
Unitree’s decision to use a lower gear ratio is part of an industry-wide trend. High gear ratios made sense for industrial robots that were programmed to perform simple, repetitive motions. In contrast, many modern robots perform complex actions in unpredictable environments. This requires sophisticated control software that can respond flexibly to changing conditions. The software is constantly making small corrections anyway, so it can compensate for less precise hardware.
The humanoid pivot
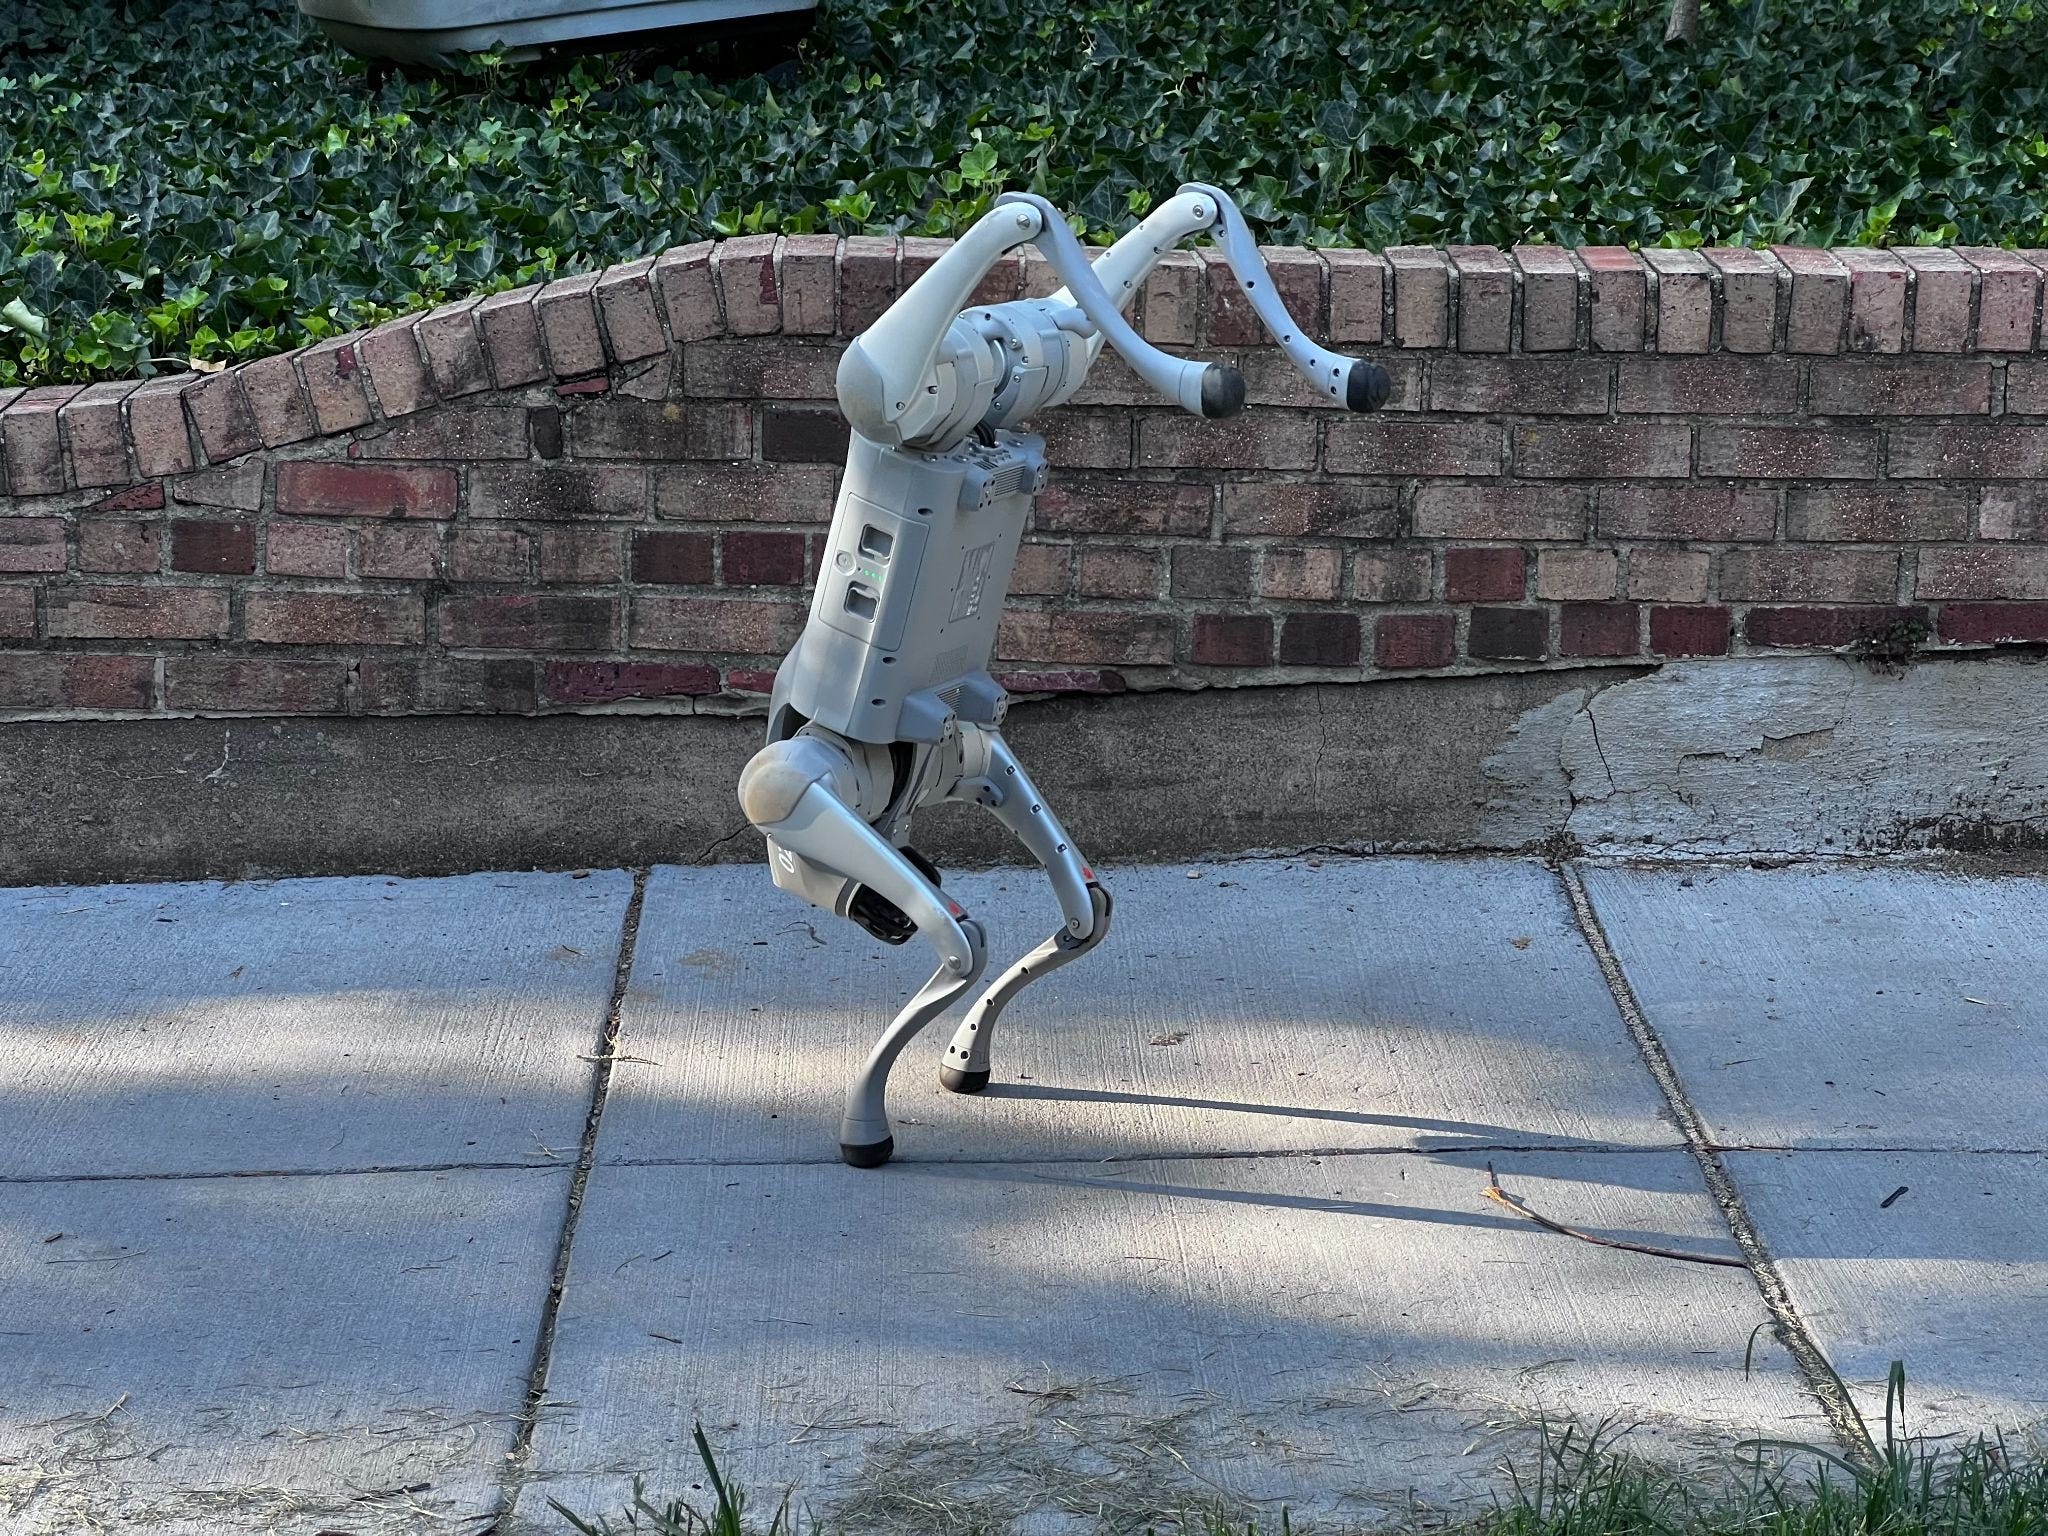
One of the most impressive and crowd-pleasing capabilities of my Go2 Pro robot dog is handstands. The robot can balance on either its front or hind legs indefinitely, and can even move forwards, backwards, or side to side while doing so.
So it was natural for Unitree to expand into humanoids. Unitree first debuted a humanoid called the H1 in 2023. The next year, Unitree unveiled a cheaper and more capable robot called the G1.
I got to see one when I visited Prof. Xuesu Xiao’s lab in June. He paid around $50,000 for a research-grade EDU version. The consumer version starts at $13,500. This is shockingly cheap given the robot’s capabilities.
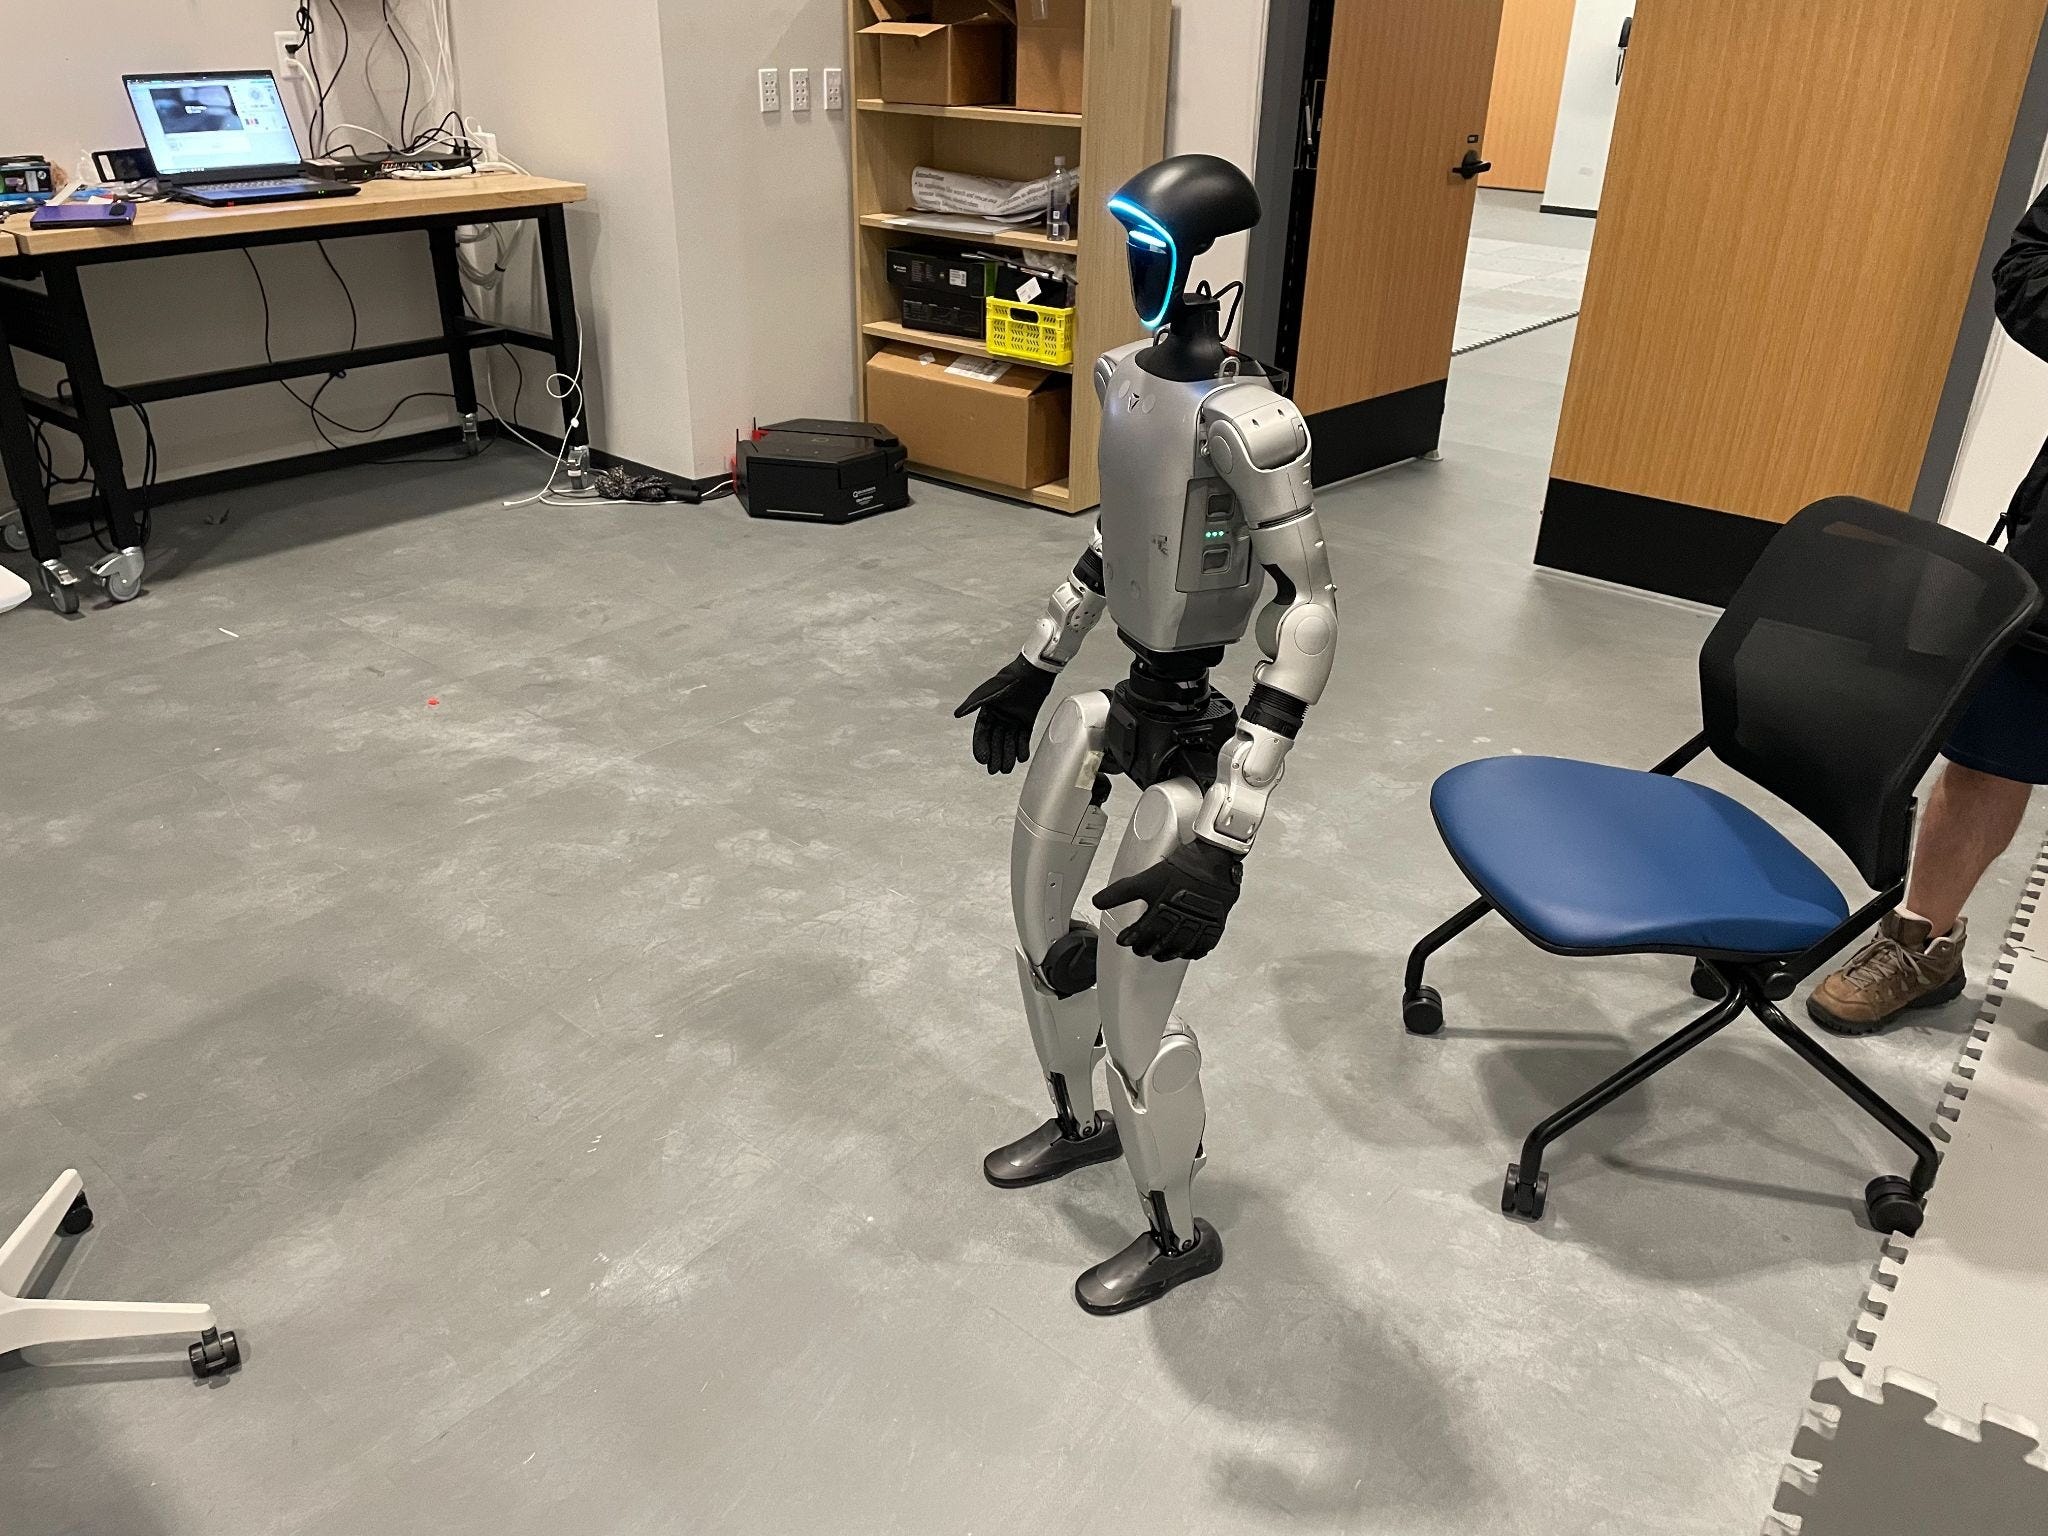
A humanoid robot is more than a quadruped standing on its hind legs. My Go2 quadruped robot has three motors per leg, for a total of 12. The cheapest G1 humanoid has five motors in each arm, six in each leg, and one in the torso, for a total of 23. The leg motors in a humanoid robot also need to be more powerful, since it’s more work to balance on two legs than to stand on four.
Still, I suspect that Unitree’s experience with quadrupeds gave it a leg up on humanoids. By the early 2020s, Unitree had been shipping quadruped robots for several years. The company had deep expertise in actuator design and an extensive network of suppliers.
According to filings connected to Unitree’s August stock offering, the company’s quadruped revenue tripled between 2024 and 2025 — from RMB 230 million ($34 million) to RMB 697 million ($104 million). The comparable figures for Unitree’s humanoids were RMB 107 million ($16 million) and RMB 867 million ($129 million) — an eight-fold increase.
Humanoids accounted for 51% of Unitree’s revenue in 2025. I expect this figure to be even higher for 2026.
Unitree could have a durable advantage
“We are witnessing the birth of another Chinese hardware giant,” wrote a team at SemiAnalysis in June. “Three years ago, Unitree was a quadruped company. By last year, they parlayed quadruped dominance into creating and leading the humanoid market.”
The SemiAnalysis authors draw a parallel to DJI, the Chinese company that dominates the global drone market.
“DJI’s Phantom 1 shipped January 2013 at $679, and was not a fully-fledged product at the time,” the SemiAnalysis team writes. “It had no built-in camera, no gimbal (stabilizer), ten minutes of flight, no live video feed, but it was roughly half the cost of the build-it-yourself drone.”
Like DJI in 2013, Unitree’s robots today have a lot of rough edges. Certainly mine does.
The app to control the robot is buggy. Features Unitree showcased in its launch video — like climbing stairs and following a human owner — don’t work well in real life. If I turn the robot on with its legs slightly out of place, they will often thrash around wildly and the robot will wind up on its back.
Then there was the time my robot collapsed just feet from my house. A more polished product might have detected the low battery (or high temperature) and shut itself down gracefully.
But for bleeding-edge technologies, this kind of polish may not be very important. Far more important is getting costs down.
“DJI chose to inhouse the most expensive and technically difficult component first: the flight controller,” SemiAnalysis writes. “Later on, DJI brought inhouse the gimbals, motors, and ESCs.”
DJI figured out how to make these components more cheaply than they could be purchased from external suppliers, which in turn allowed it to undercut other drone makers. And that expanded the market for DJI’s drones.
Before DJI came along, “professional aerial photography was the domain of helicopters and Hollywood second-unit teams, but now, small businesses could perform this on their own. As such, whole new markets were unlocked for DJI, like real estate listings, wedding videos, local news, agricultural surveying.”
There’s a flywheel here: the more units a company sells, the better deals it can negotiate with suppliers and the more money it can spend optimizing its manufacturing process. Larger sales volumes also allow a company to bring more components in house. This allows the company to push costs even lower, which will mean more sales and even more money to invest in improving the production process.
Over a few years, this flywheel helped DJI to dominate the global drone market. SemiAnalysis argues that Unitree is on track to do the same thing for legged robots.
According to SemiAnalysis, Unitree has developed its own motors, gearboxes, lidar sensors, and cameras. “Unitree’s self-produced motors can run as low as 30-40% of equivalent Western motors,” SemiAnalysis reports. “They now make some of the cheapest humanoid gearboxes in the world.”
This could enable Unitree to take over the global market for quadruped and humanoid robots in much the same way that DJI took over the global drone market.
Of course that’s not guaranteed to happen. Unitree has a number of Chinese rivals. Unitree is the global leader in quadrupeds, but a Chinese rival, AgiBot, has sold more humanoid robots than Unitree in recent months. There are also many smaller robot companies in China that could challenge Unitree and AgiBot in the coming years.
But Unitree does not face much competition in the United States or the West more generally. Boston Dynamics sells excellent robots, but they tend to be significantly more expensive. There are a number of American startups aiming to build humanoid robots, including Tesla, Figure, and 1X, but consumers cannot buy a robot from any of these companies today.
That has alarmed some American policymakers. In June, a bipartisan group in the House introduced a bill to restrict importation of Chinese robots. The official press release for the legislation mentioned Unitree by name. Then in July, the FCC imposed broad new regulations on foreign-made robots that are likely to impact Unitree and other Chinese companies.
However, the robot market is global. Even if Chinese companies get locked out of the US market, Unitree or one of its Chinese rivals could still come to dominate the global market for humanoid robots.
There’s an obvious parallel here to electric vehicles, where Chinese companies like BYD are effectively banned from the US but are making rapid gains in the rest of the world. There’s a risk that a ban on Chinese robots could have a similar impact: rather than hampering the growth of companies like Unitree, it could make the US a robotics backwater.
If you enjoyed this article, please support our work with a paid subscription. This week we’re offering 25% off an annual subscription!
Unitree makes larger quadruped robots like the B2, which seems to start around $85,000. It is unclear to me how to do an apples-to-apples comparison with Spot, which also comes in multiple configurations and is not priced transparently.
To avoid logistical hassles, I bought my robot from an eBay vendor in Pennsylvania. This added a few hundred dollars to the cost.
A possible use case: the dog can walk the human.
This would give the human some exercise
Why robots cain't ever be cowboys.
The core engineering bottleneck that lab demonstrations routinely gloss over is organic resilience and self-healing under extreme chaotic wear.
The Impact Problem: High-torque planetary gearboxes, cycloidal drives, and harmonic reducers hate sudden shock loads. Catching an errant hoof, taking a tumble down a rocky draw, or absorbing mud, grit, and torrential rain will shear gear teeth or seize bearings in short order.
Self-Repair vs. Supply Chains: Biological tissue can absorb dynamic micro-trauma, remodel bone density, regenerate muscle tears, and maintain its own lubrication continuous-duty for decades. A broken robotic limb requires a clean workspace, custom replacement actuators, specialized tooling, and downtime.
Environmental Sealing: The moment fine dust, river water, freezing slush, or abrasive grime meets an actuator seal or exposed rotary joint, friction spikes, internal temperatures climb, and the platform faults.
Until machines are grown out of self-repairing synthetic musculature rather than machined aluminum, copper coils, and silicon boards, the high-friction, unscripted punishment of the open range remains strictly biological territory.